D-Sub interface endD-Sub接口端
The D-Sub-form end allows equipment connection to be arranged around the mating face, fixing screws and rear cable route.端头采用D-Sub形式,可围绕插合面、固定螺钉和后部线缆走向安排设备连接。
D-sub & Circular Connector Robot Harness combines d-sub interface end, circular connection end, plug-in connection end. Interface, circuit and installation data guide dimensions, material selection and sample review.D-SUB与圆形接头机器人连接线束的结构重点包括D-Sub接口端、圆形连接端、插接式端头。接口、电路与安装资料将作为尺寸、物料和样品制作的确认依据。
Use the d-sub & circular connector robot harness form as a starting point and confirm these design points against drawings and the actual equipment.以D-SUB与圆形接头机器人连接线束的结构形式为起点,结合图纸和实际设备确认以下设计要点。
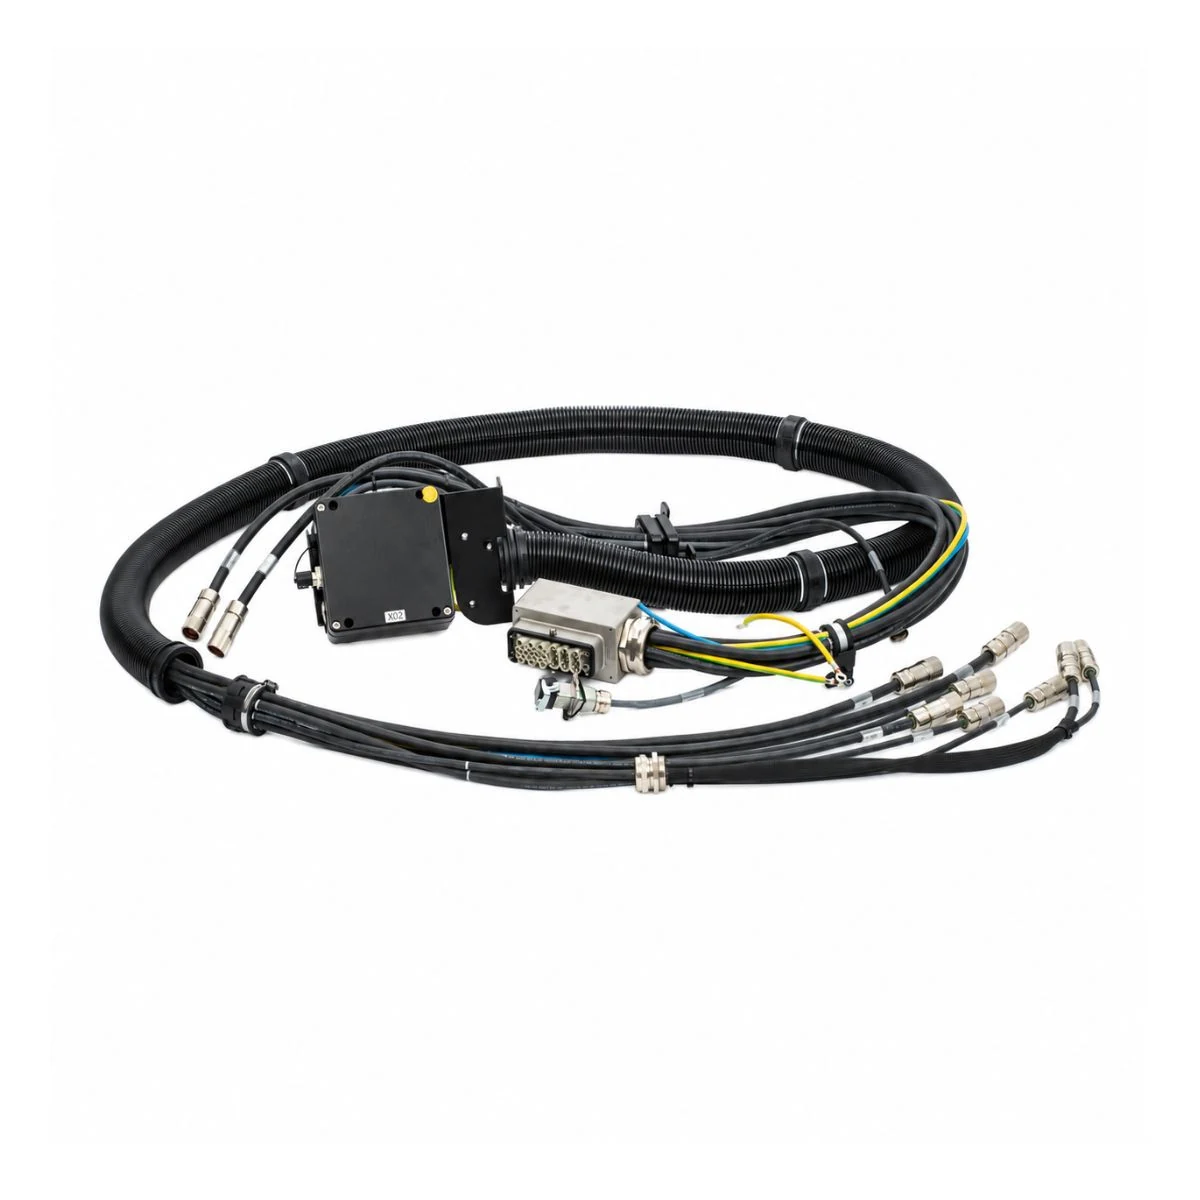
The D-Sub-form end allows equipment connection to be arranged around the mating face, fixing screws and rear cable route.端头采用D-Sub形式,可围绕插合面、固定螺钉和后部线缆走向安排设备连接。
The end uses a circular interface form, with connection positions planned around mating direction, retention and cable exit.端头具有圆形接口形式,可围绕对插方向、端部固定和线缆出口规划连接位置。
The end uses a plug-in form, with clearance arranged for insertion, removal and cable bends.端头采用插接形式,可围绕安装位置安排插入、退出及线缆弯曲空间。
Match the series, keying, contact count, mating direction and locking method. Similar shell outlines do not establish compatible dimensions or contact assignments.接口选型需核对系列、键位、针数、插合方向与锁紧方式;相近外形不能替代对插尺寸和接点定义。
Review contact mapping, screw or latch retention, backshell space and cable exit together. Keep contact positions and circuit revision identifiable after assembly.针位对应、螺钉或锁紧结构、后壳空间和出线方向需要一起审核,装配后应能够识别针位和电路版本。
The table describes the construction and available configuration choices. Materials, dimensions, circuits and inspection requirements are agreed for each project.以下说明展示结构与可配置内容。具体材料、尺寸、电路和检验要求按项目确认。
| Axis motion path, travel and torsion angle各轴运动路径、行程与扭转角 | Distinguish bending, carrier motion and torsion by the real axis path.按实际轴路径区分弯折、拖链和扭转工况。 |
|---|---|
| Dynamic bend radius, speed and target cycles动态弯曲半径、速度及循环目标 | Define radius, speed, travel and cycle targets within one validation profile.半径、速度、行程与循环目标放在同一验证条件中。 |
| Servo power, encoder and communication circuits伺服动力、编码器与通信电路配置 | Allocate power, brake, encoder and communication paths to the drive definition.动力、制动、编码器与通信按驱动定义分区。 |
| Clamp positions, service loops and joint routing space夹持位置、服务环与关节穿线空间 | Place clamps, service loops and passages around the full motion envelope.夹持、服务环和穿线口随完整运动包络安排。 |
| Circuit and revision reference电路与版本依据 | Do not select only by conductor count.不能只按芯数选型。 |
| Sample and manufacturing configuration样品与制造配置 | The sample stage confirms routing length, clamp points and connector orientation before motion testing by the customer or an agreed method. Production specifications are frozen only after the sample and motion conditions are accepted.样品阶段先确认布线长度、固定点和接口方向,再由客户或按约定方法进行运动验证;样品与运动条件确认后,才冻结量产规格。 |
These are connection directions for project discussion. Suitability depends on interfaces, circuits, installation conditions and project validation; configuration can be adapted to the equipment.以下为可讨论的连接方向。实际适用性取决于接口、电路、安装环境和项目验证,可按设备需求调整。
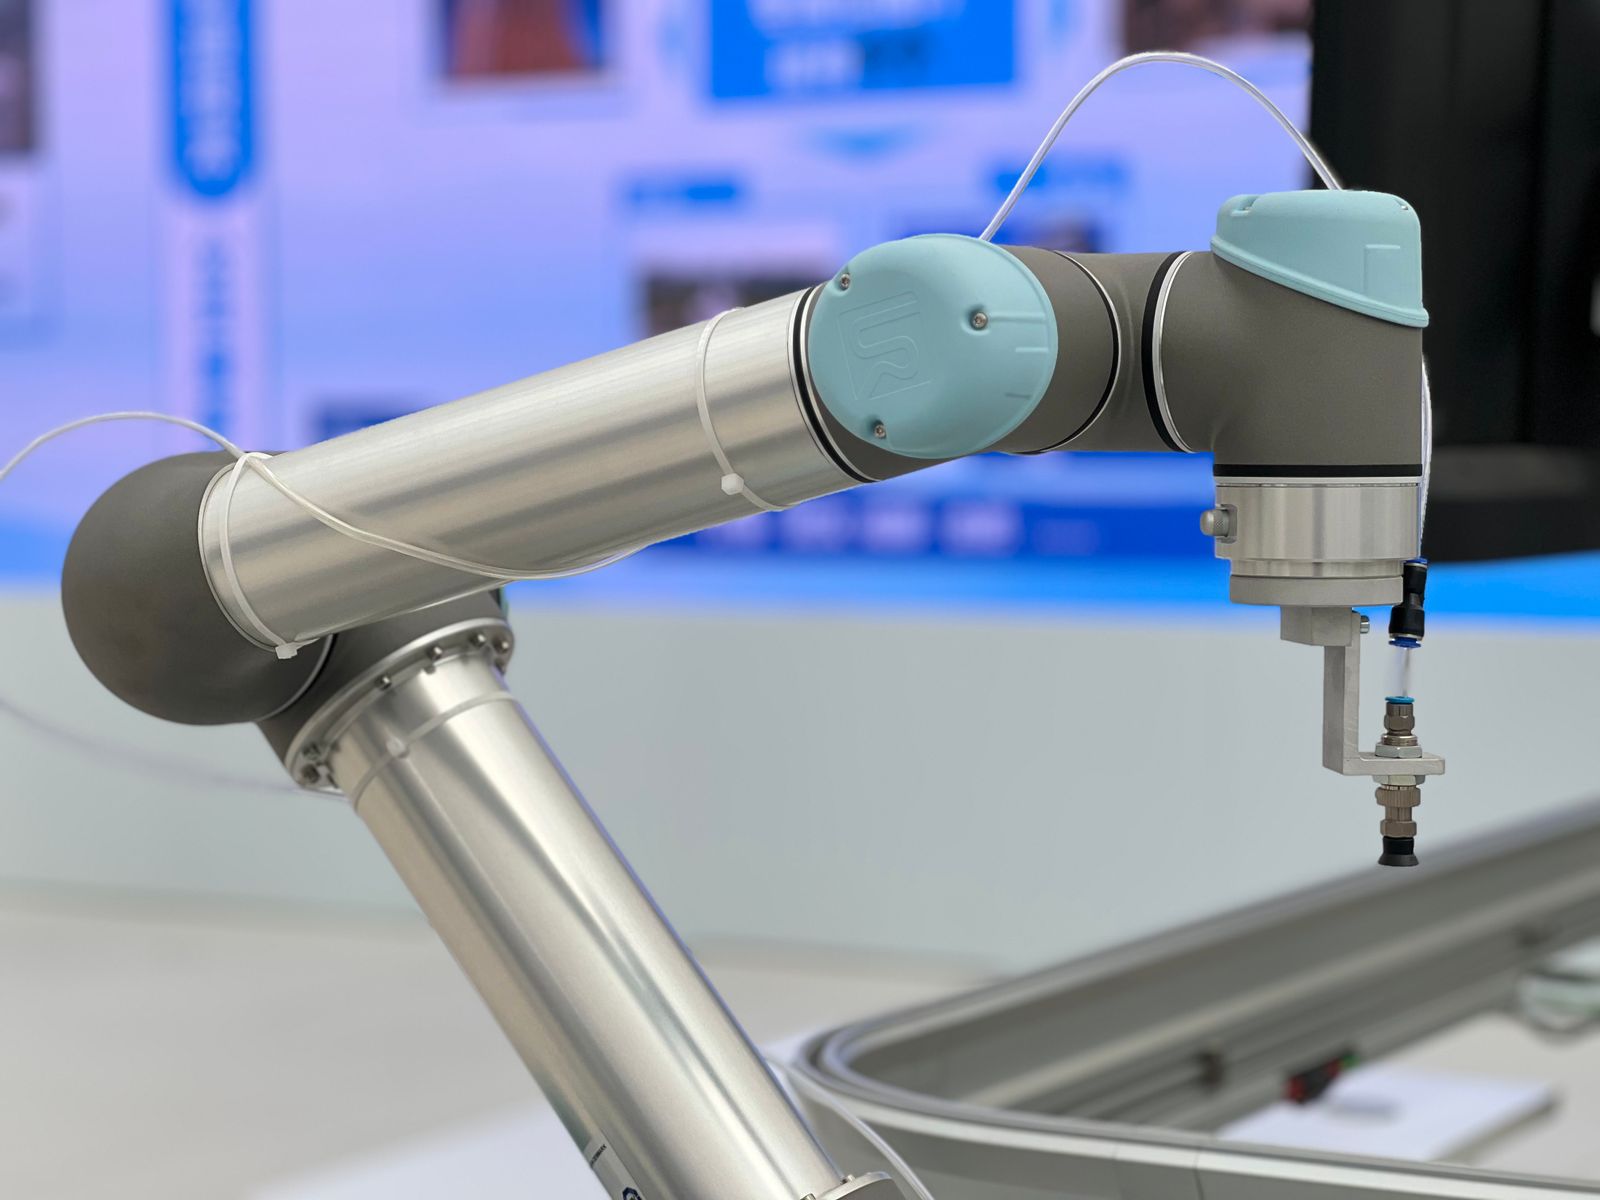
Axis power, encoders, sensors, grippers, valves and safety interfaces on automated lines. Distinguish bending, carrier motion and torsion by the real axis path.自动化产线中的轴动力、编码器、传感器、夹具、阀组和安全接口。选配时,按实际轴路径区分弯折、拖链和扭转工况。
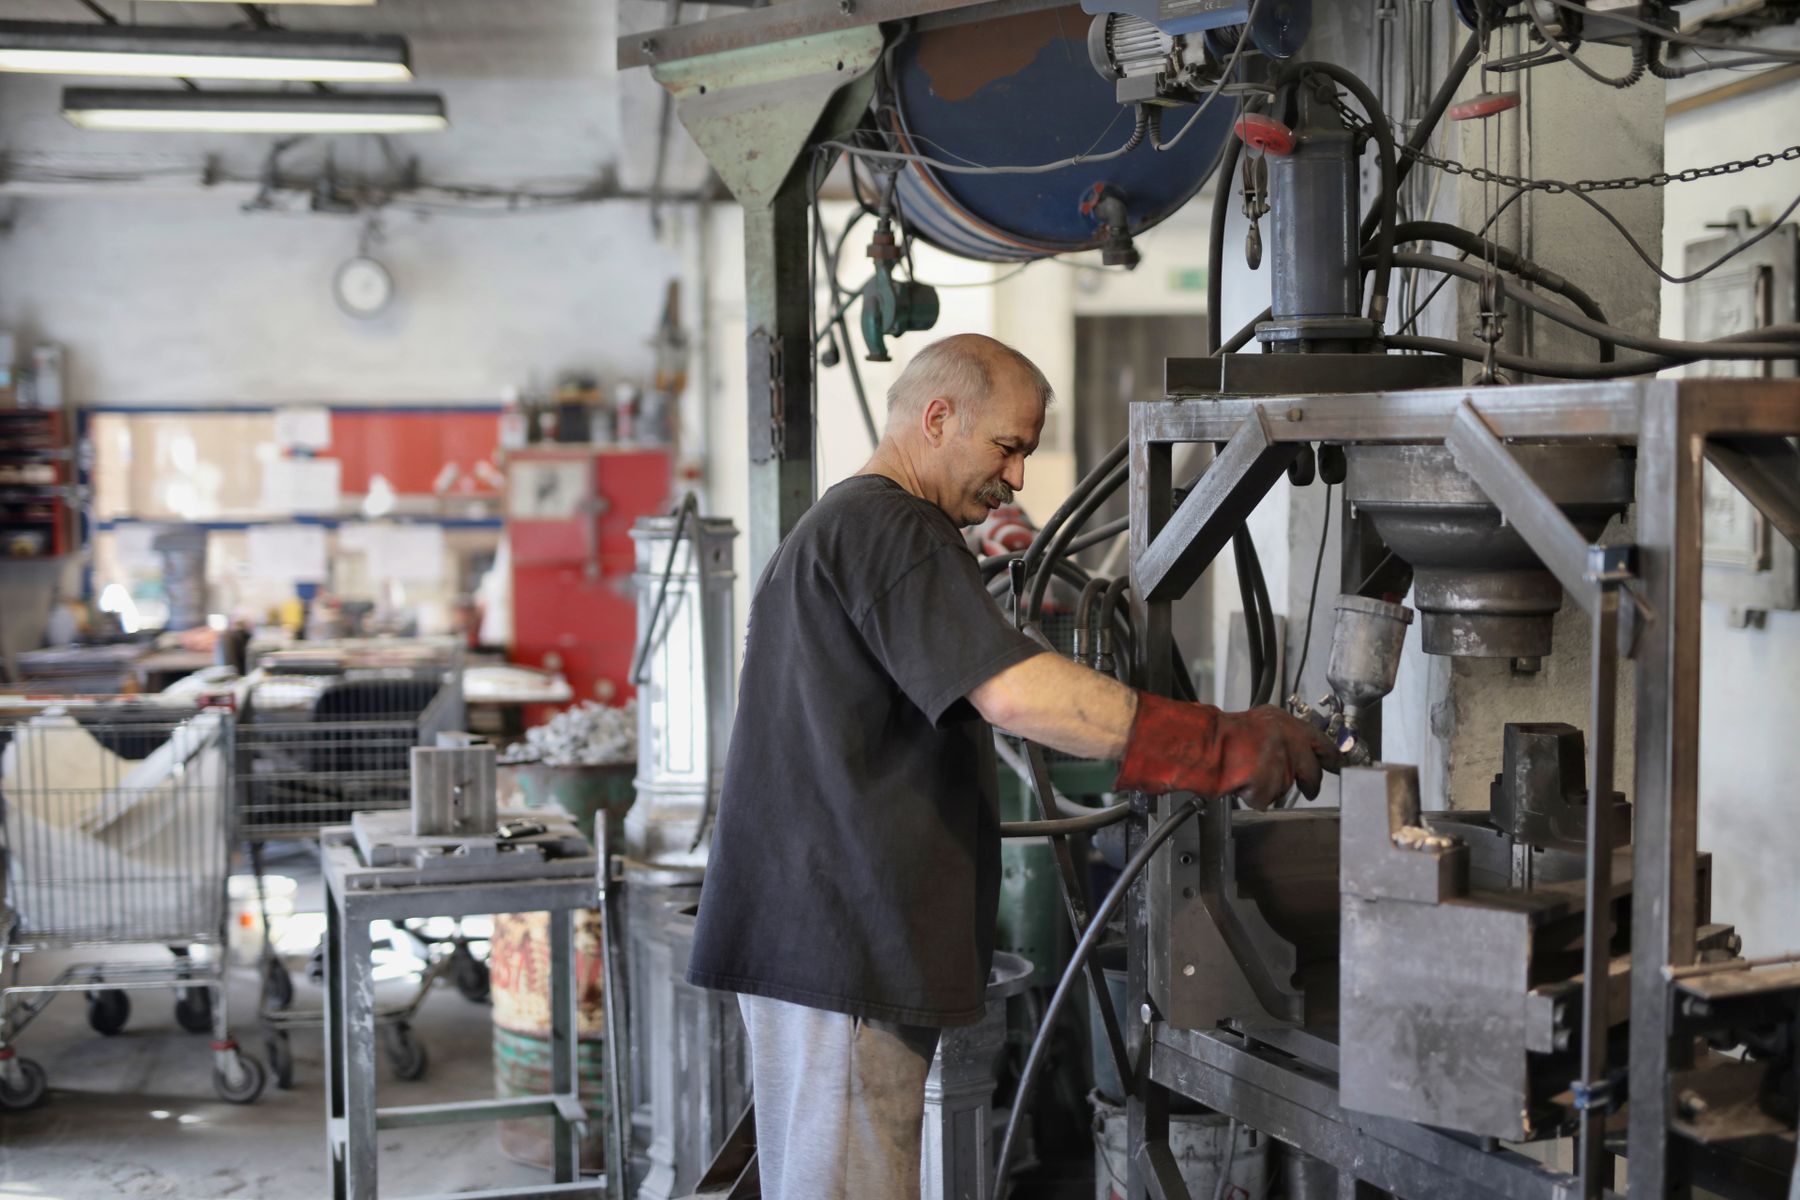
Dress packs and tool circuits exposed to repeated motion, heat, sparks and shop-floor contact. Define radius, speed, travel and cycle targets within one validation profile.承受重复运动、热量、飞溅和车间接触的随动线束与工具回路。选配时,半径、速度、行程与循环目标放在同一验证条件中。
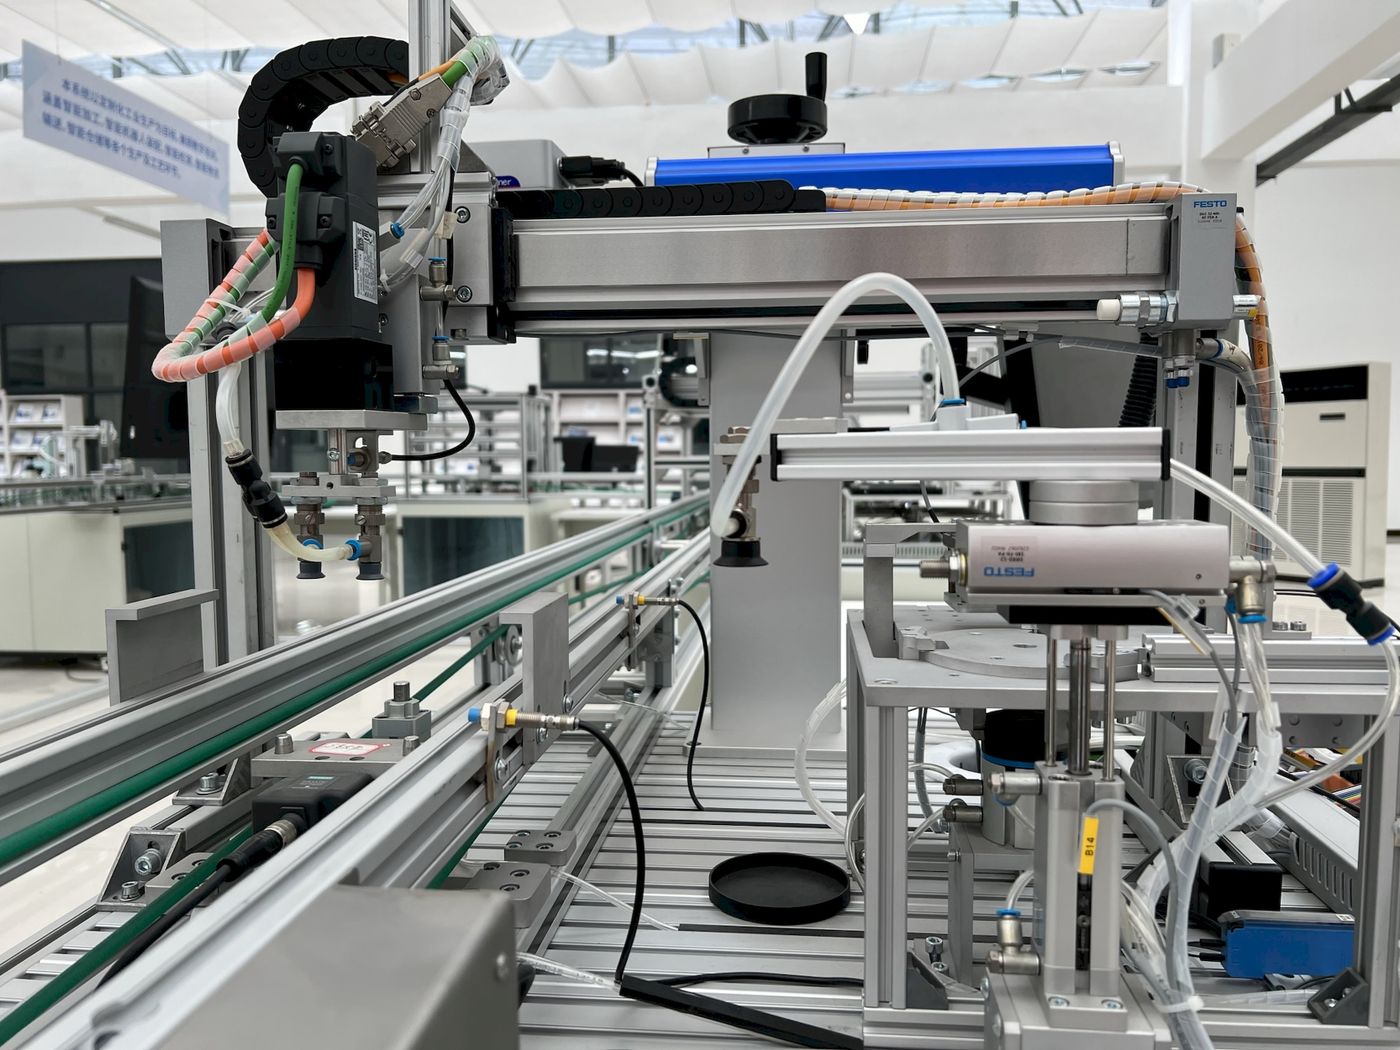
Compact lightweight routing for fast axes, end effectors, sensors and machine interfaces. Allocate power, brake, encoder and communication paths to the drive definition.面向高速运动轴、末端执行器、传感器和设备接口的紧凑轻量化布线。选配时,动力、制动、编码器与通信按驱动定义分区。
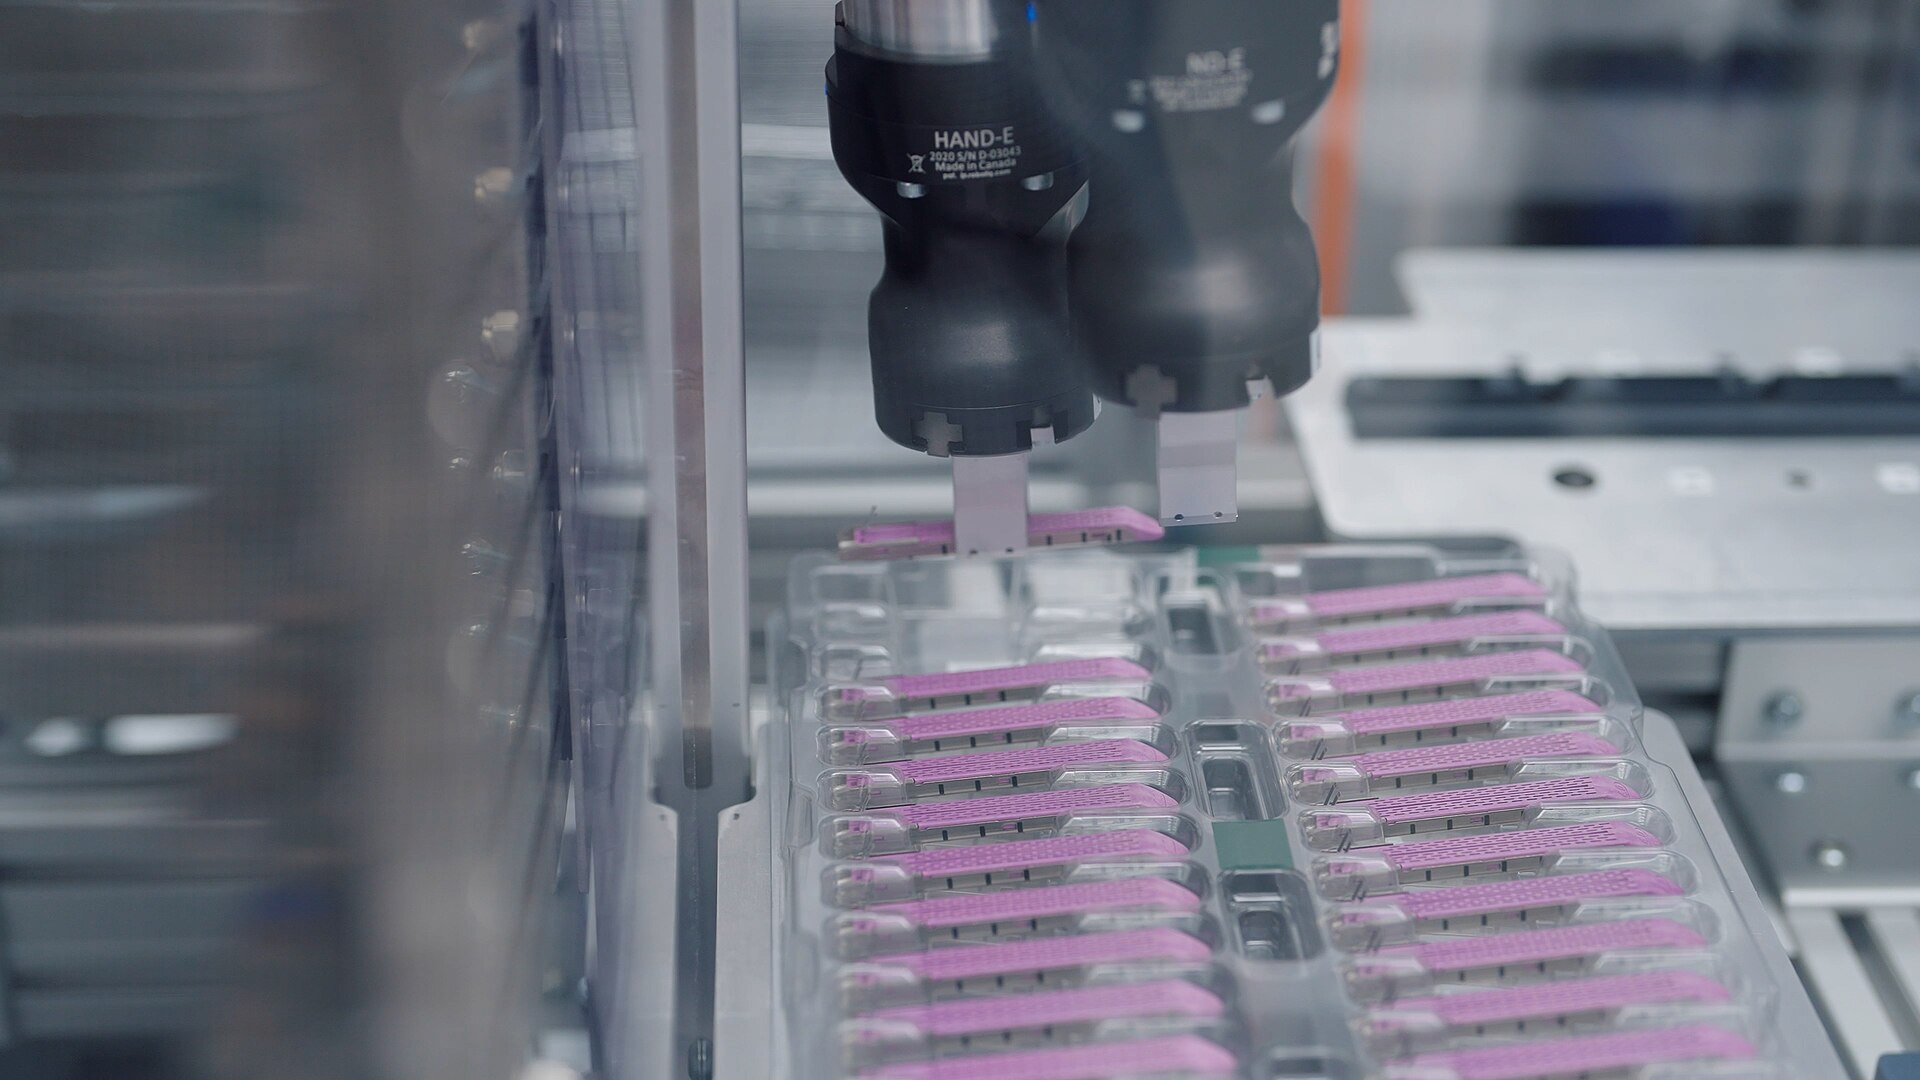
Low-voltage power, control, sensing and communication inside compact articulated systems. Place clamps, service loops and passages around the full motion envelope.紧凑多关节系统内部的低压电源、控制、传感与通信连接。选配时,夹持、服务环和穿线口随完整运动包络安排。
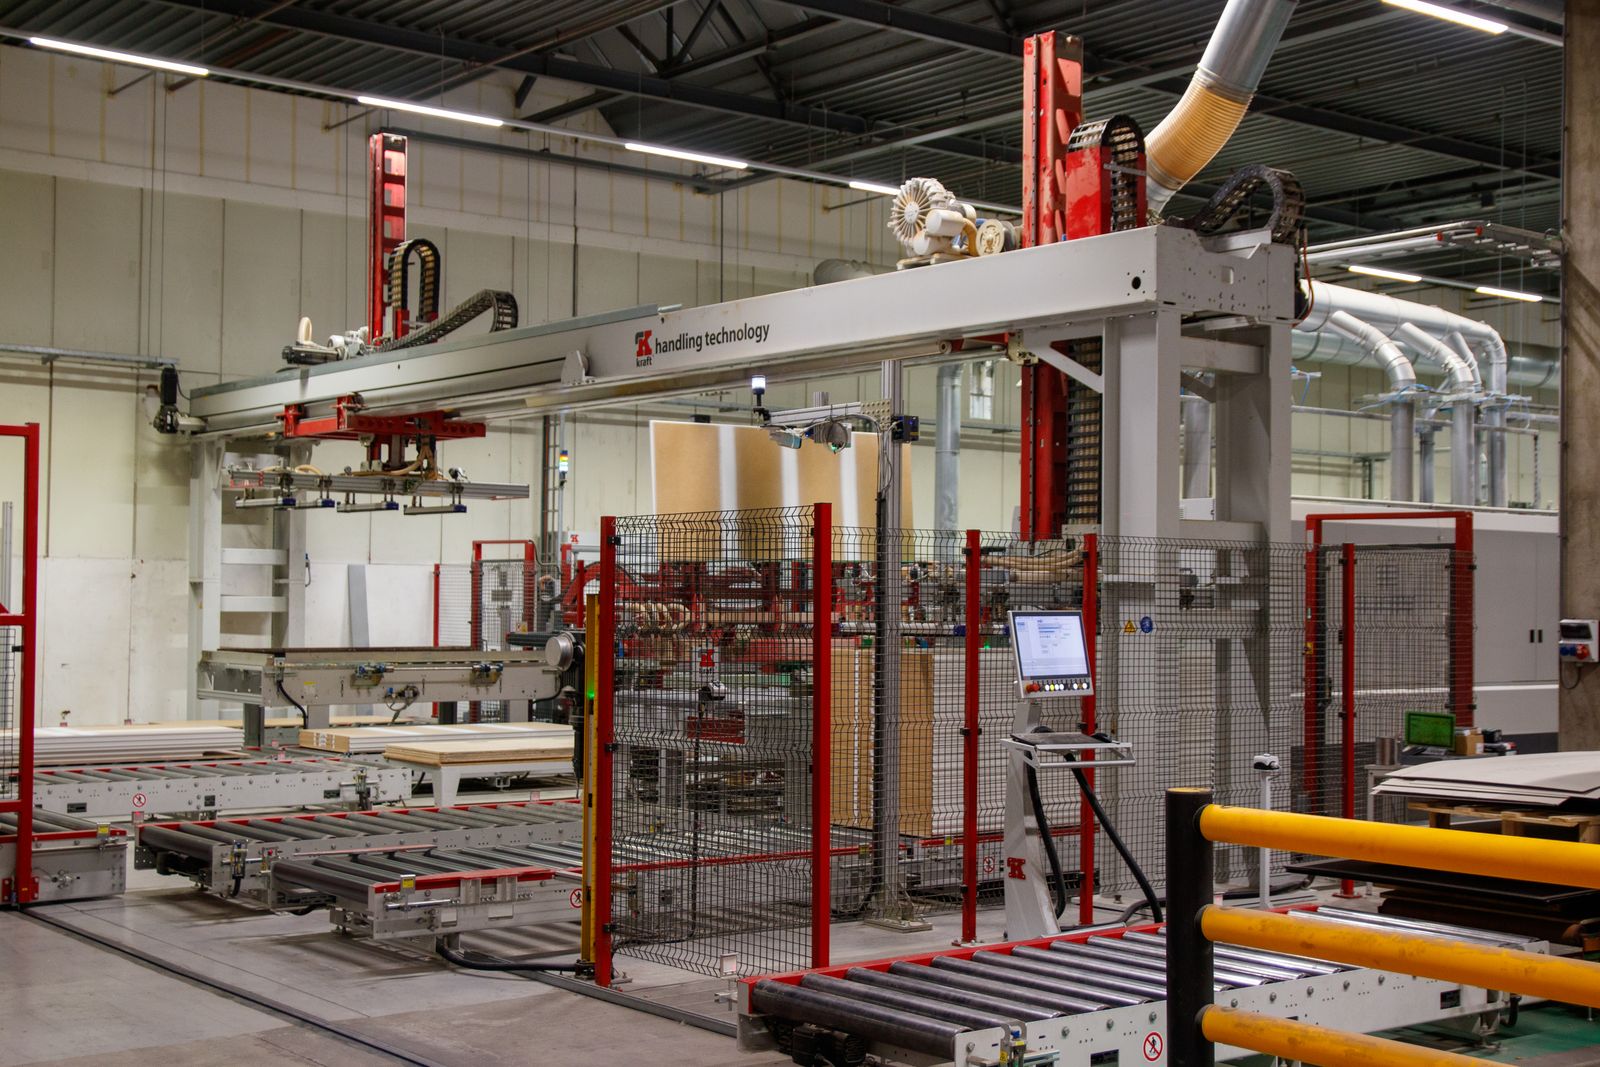
Carrier-guided power, signal and feedback assemblies for long repetitive travel. Distinguish bending, carrier motion and torsion by the real axis path.用于长距离往复行程的拖链动力、信号与反馈组件。选配时,按实际轴路径区分弯折、拖链和扭转工况。
Robot-to-machine interfaces for doors, grippers, presence sensing and production control. Define radius, speed, travel and cycle targets within one validation profile.用于柜门、夹具、到位检测和生产控制的机器人至机床接口。选配时,半径、速度、行程与循环目标放在同一验证条件中。
Our China factory supports robotic harness projects through custom wire harness manufacturing and OEM/ODM development. Interface, circuit and installation data guide material selection, sample builds and manufacturing-document approval before repeat production.Super Smile-Tech 中国工厂围绕机器人线束的项目需求提供定制线束制造与 OEM/ODM 支持。我们从接口、电路与安装资料开始,协同物料选配、样品制作和制造文件确认,再按批准要求组织重复生产。
Review pin definitions, axis layout, motion path, stroke, torsion, bend radius, clamp locations, electrical load and installation sequence before sampling.打样前审核针脚定义、轴布局、运动路径、行程、扭转、弯曲半径、固定位置、电气负载与安装顺序。
A reference assembly can establish interfaces and routing, but hidden electrical functions and the real motion profile still require customer confirmation.参考组件可用于确认接口与路径,但隐藏的电气功能和真实运动曲线仍需客户确认。
Tool-side, arm-side and cabinet-side segments can use agreed interface boundaries so one serviced branch does not require replacing the full dress pack.工具端、臂端与柜端可设置约定接口边界,使单个检修分支无需更换整套随动线束。
Not necessarily. Linear bending and multi-axis torsion impose different loads. The actual path, bend radius, torsion and clamp layout must be reviewed.不一定。直线弯折与多轴扭转产生的载荷不同,必须审核真实路径、弯曲半径、扭转和固定布局。
Provide drawings or samples, pin definitions, circuit functions, robot or axis layout, motion path or video, stroke, bend radius, torsion, environment, quantity and testing needs.建议提供图纸或样品、针脚定义、回路功能、机器人或运动轴布局、运动路径或视频、行程、弯曲半径、扭转、环境、数量和测试需求。
A sample can establish dimensions, interfaces and visible construction. Electrical function, hidden components and the real motion profile still require customer confirmation.样品可用于确认尺寸、接口和可见结构,但电气功能、隐藏元件与真实运动曲线仍需客户确认。
Share mating interfaces, a circuit table, target lengths or a sample for the d-sub & circular connector robot harness. We can use them to review configuration and sample requirements.提供D-SUB与圆形接头机器人连接线束的对插接口、回路表、目标长度或参考样品,我们据此梳理选配与样品确认事项。